




软件

产品


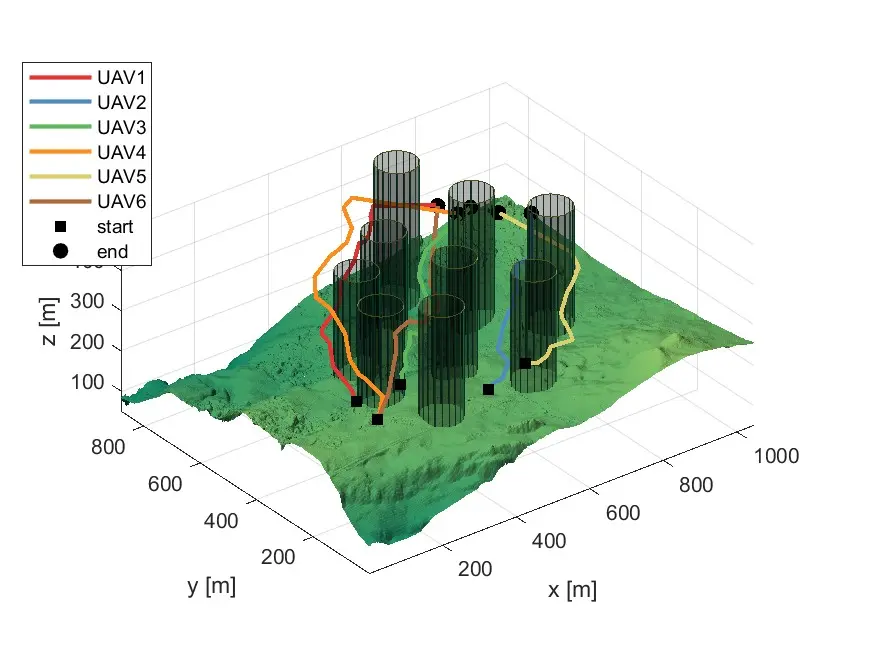
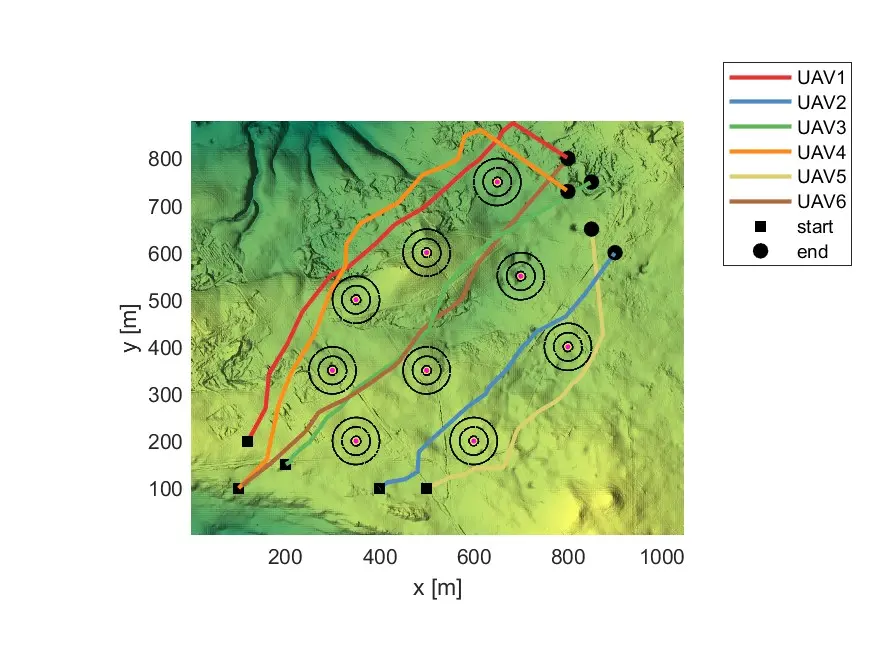
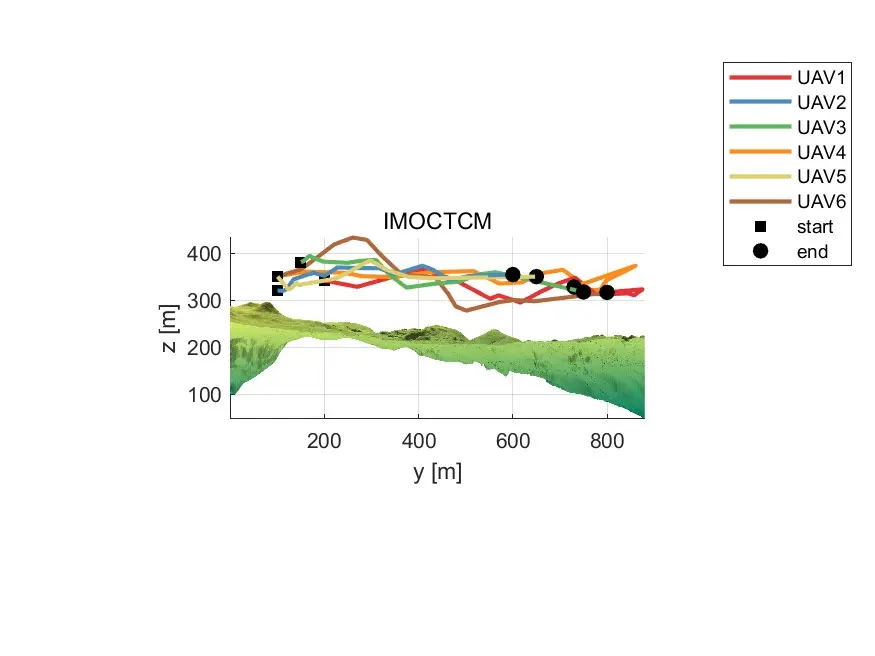
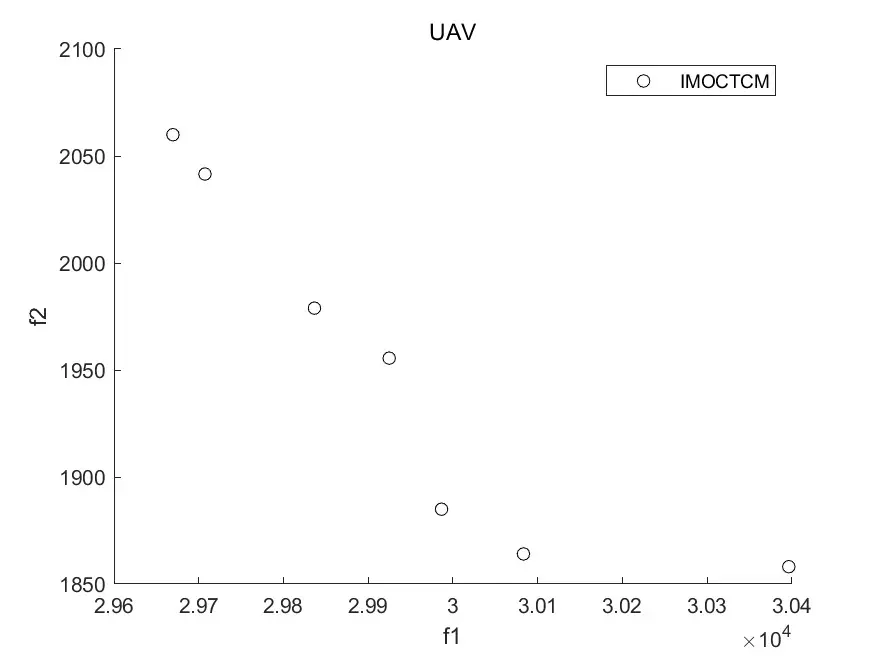
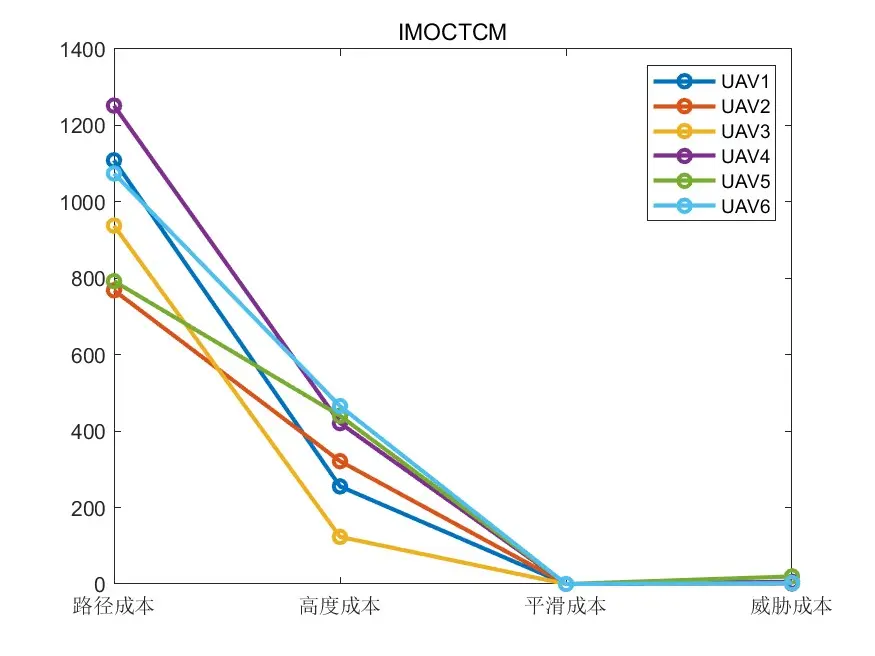
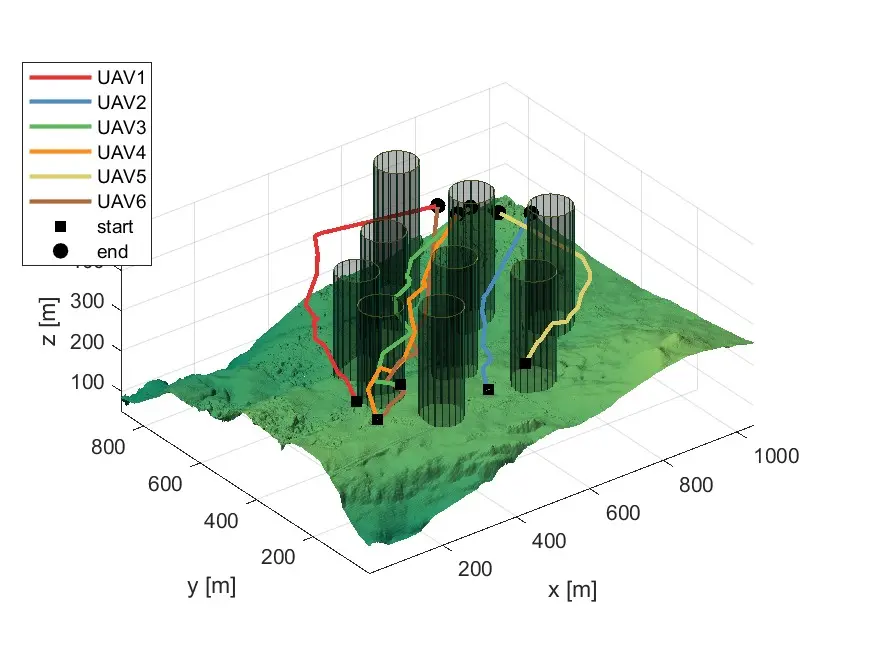
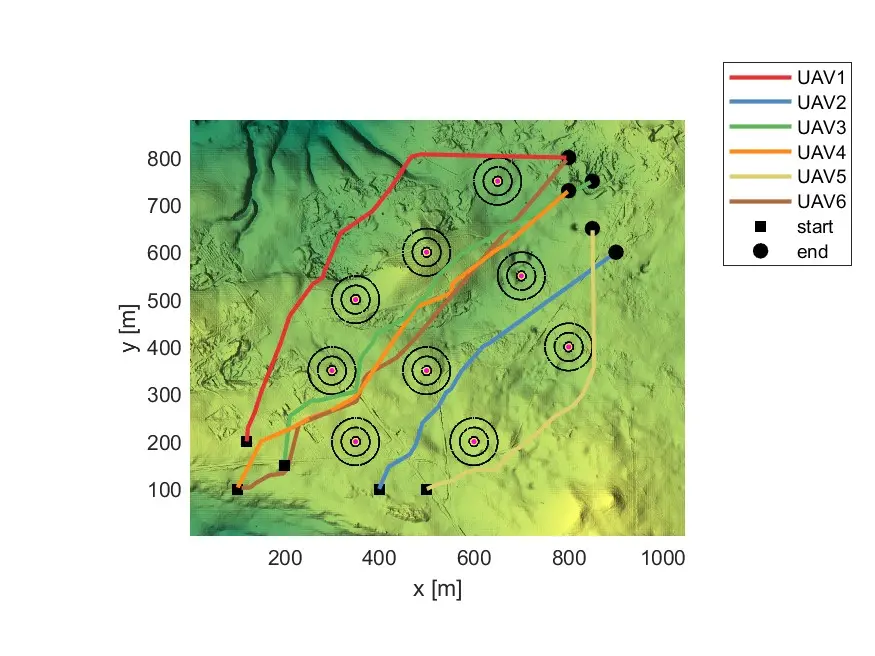
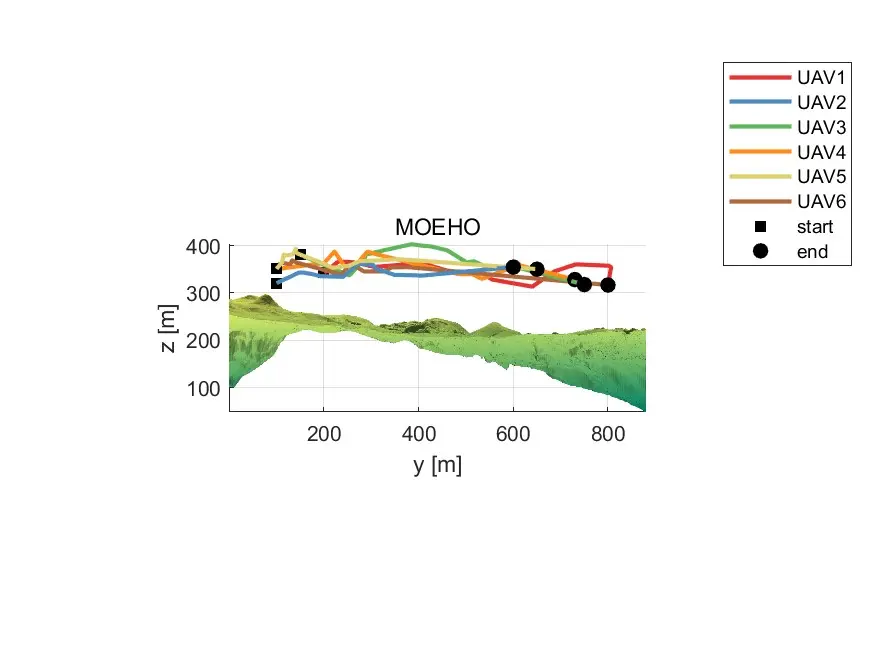
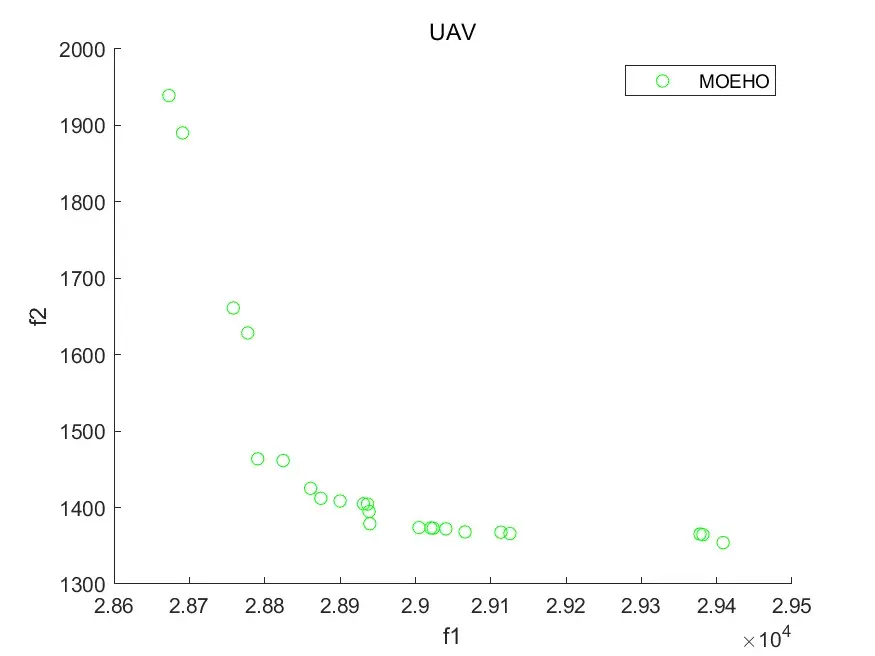
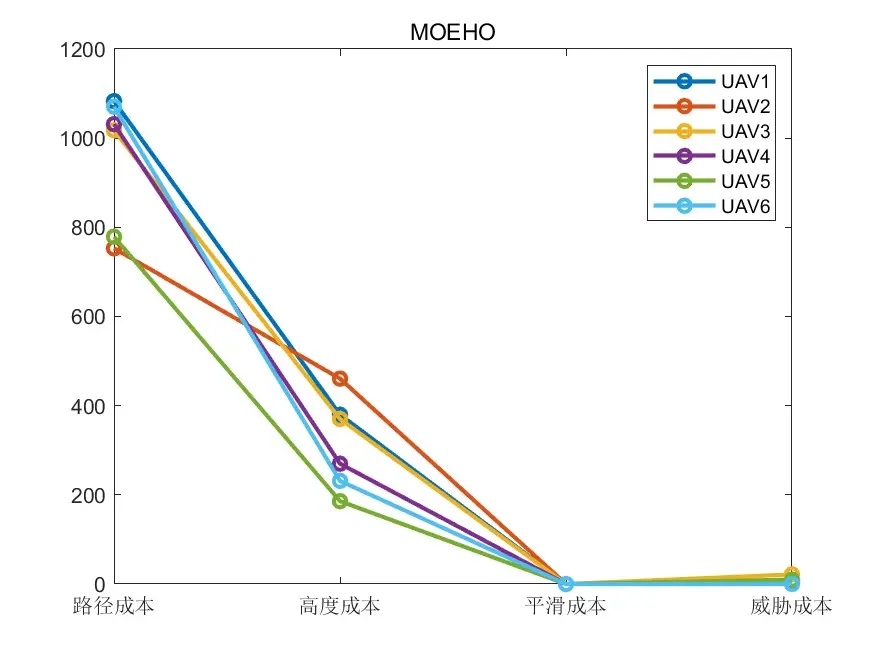
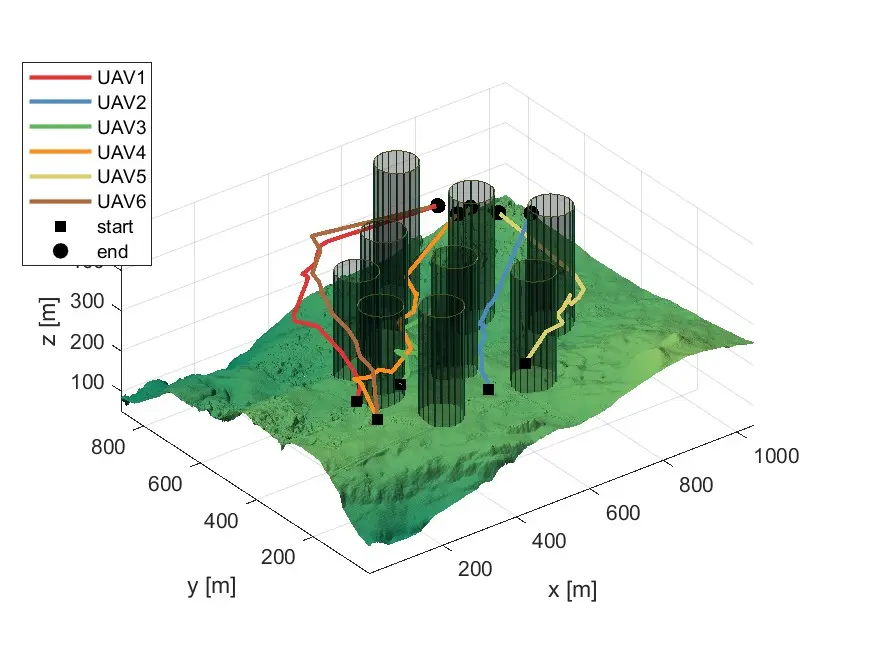
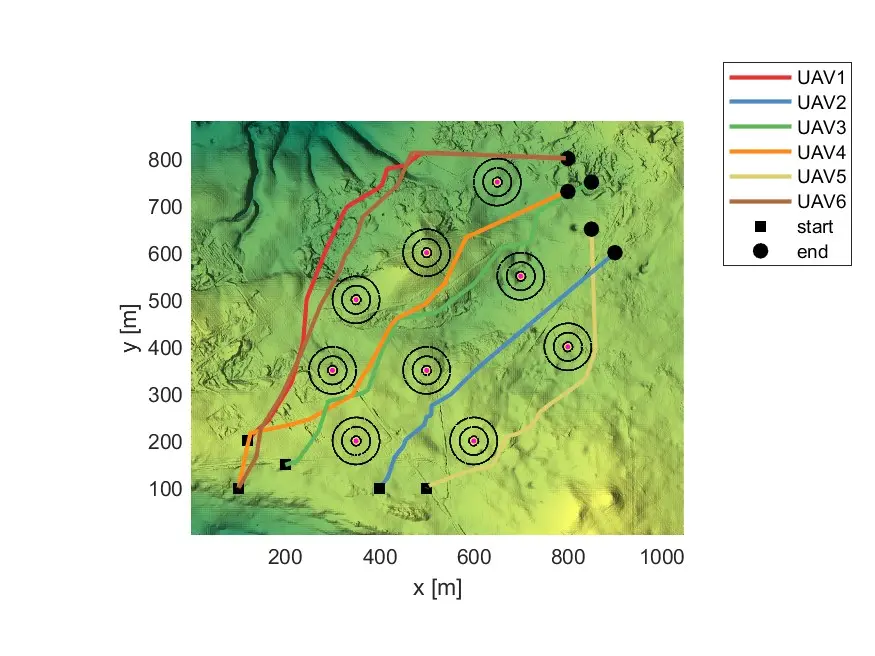
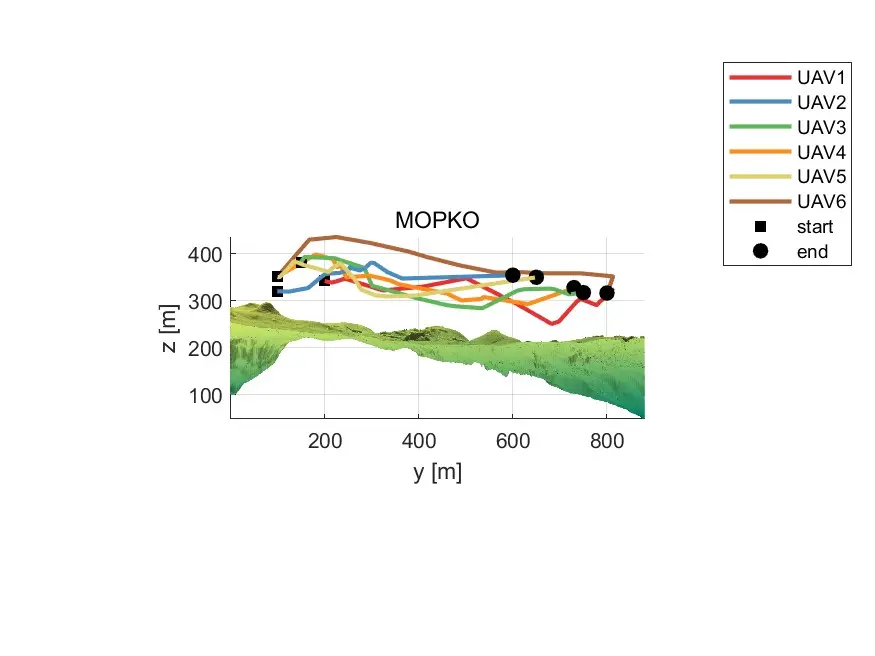
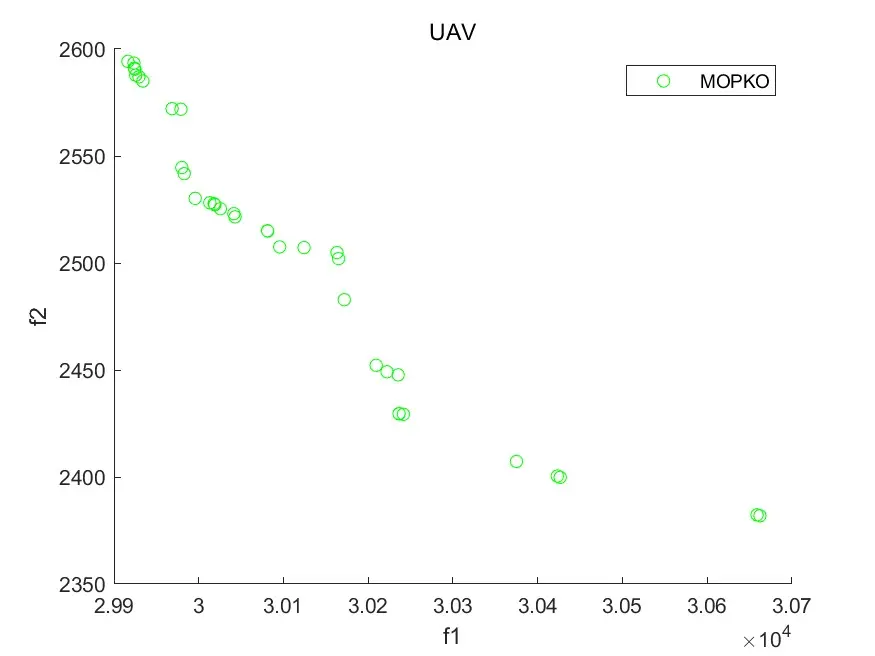
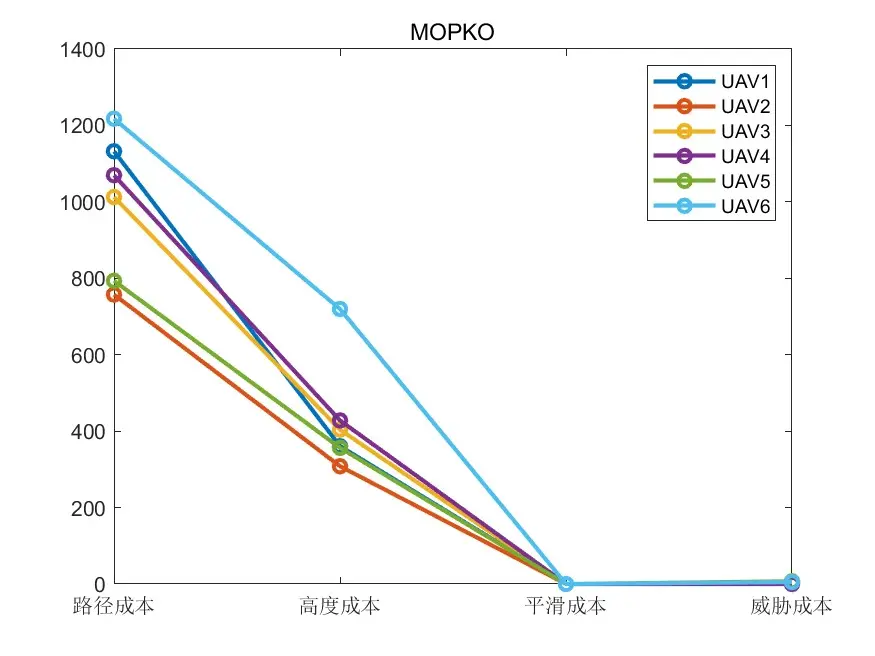
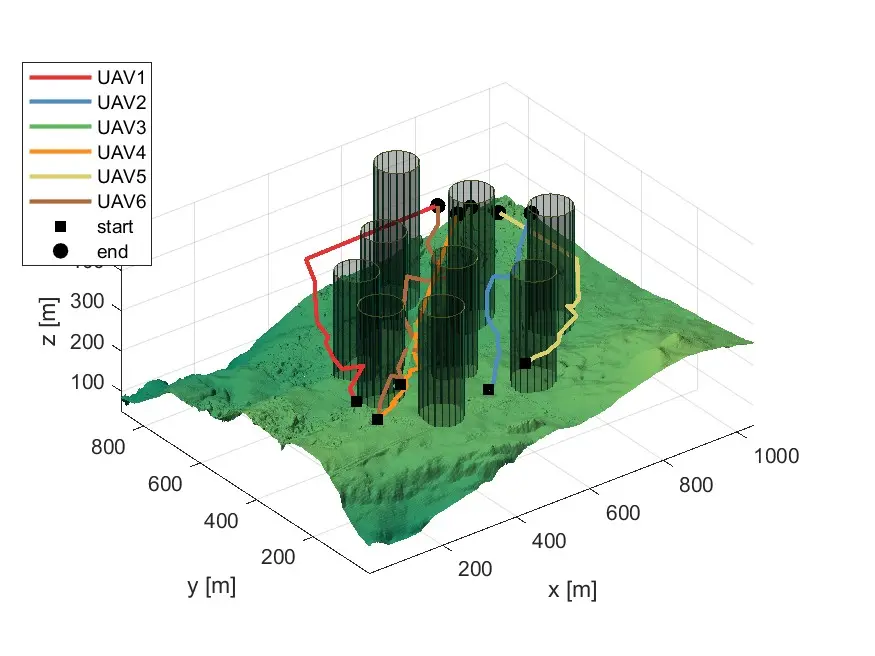
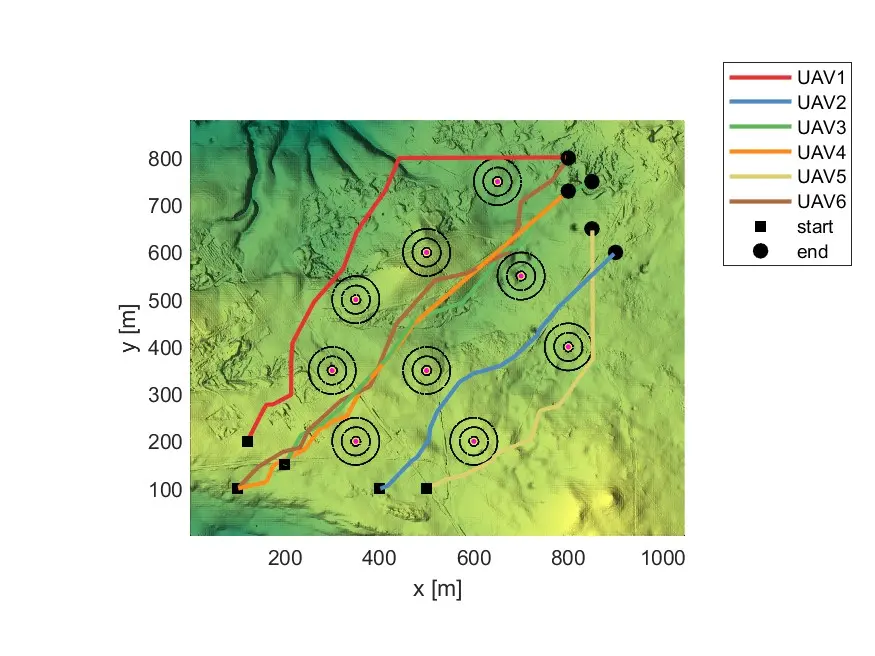
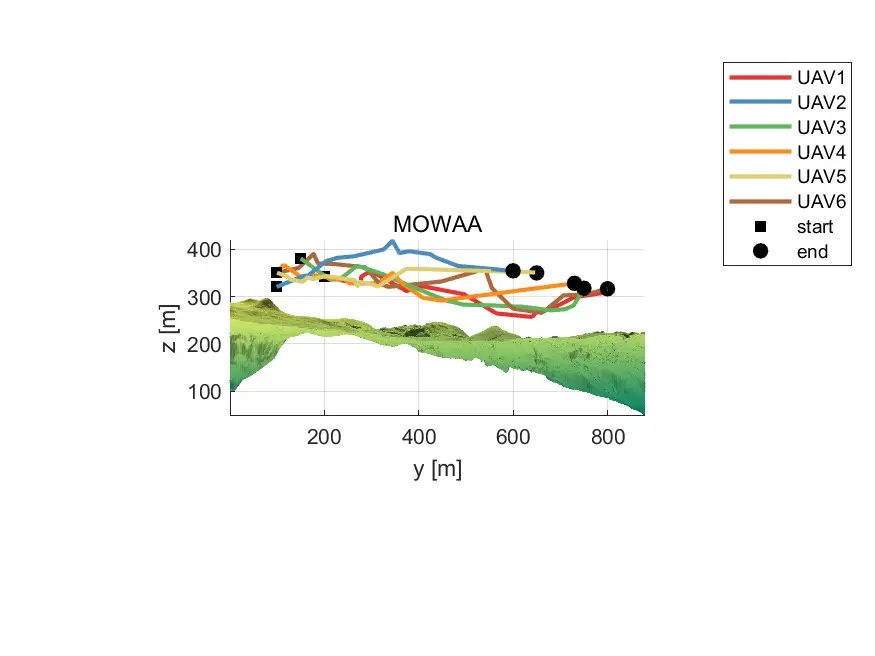
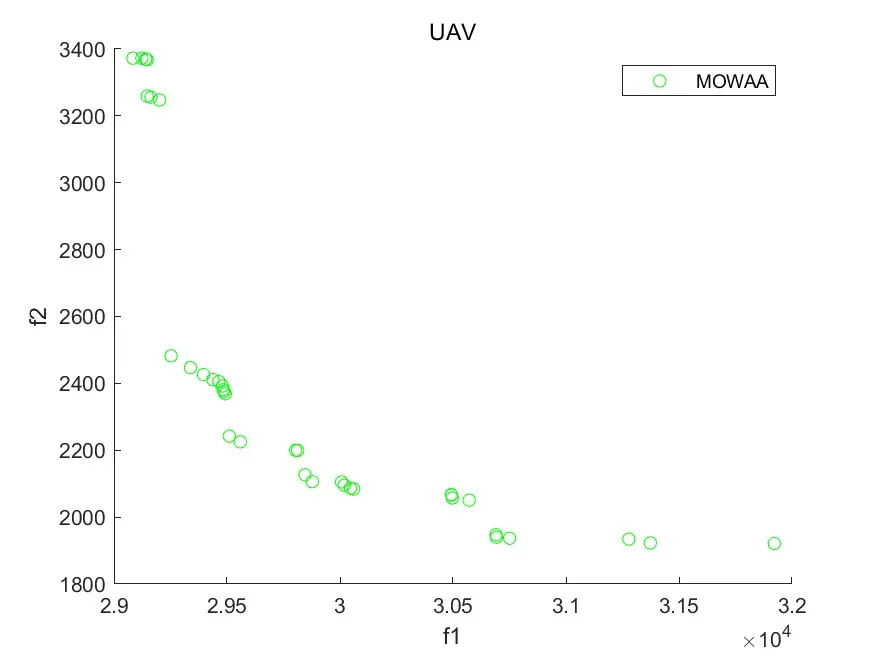
融合高斯扰动与竞争学习的改进型多目标部落竞争与成员合作算法(IMOCTCM)求解多无人机协同路径规划(多起点多终点,起始点、无人机数、障碍物可自定义)
完整MATLAB代码:
https://mbd.pub/o/bread/mbd-YZWVl59raQ==
代码块
%% 画图
lineColor=linspecer(UAVnum);%%路径颜色
for Anum=1:length(AlgorithmName)
    Result=FinalResult(Anum).Algorithm.Result;
    %% 定义3个视图
    gca1=figure;
    gca2=figure;
    gca3=figure;
    %% 画地形图及起始点
    [hh2,hh3,hhh2,hhh3,hhhh2,hhhh3]=PlotUAVRoute(ModelUAV,gca1,gca2,gca3);
    %% 画各个无人机的路径
    hh=[];
    hhh=[];
    hhhh=[];
    lenstr=[];
    for i=1:UAVnum
        [hh10,hhh10,hhhh10]=PlotUAV(Result(i).BestPosition,ModelUAV(i).model,gca1,gca2,gca3,lineColor(i,:));
        hh=[hh,hh10];
        hhh=[hhh,hhh10];
        hhhh=[hhhh,hhhh10];
        lenstr{i}=strcat('UAV',num2str(i));
    end
    legenstr=lenstr;
    lenstr{i+1}='start';
    lenstr{i+2}='end';
    legend([hh,hh2,hh3],lenstr,Location="best")
    title(AlgorithmName{Anum})

    legend([hhh,hhh2,hhh3],lenstr,Location="best")
    title(AlgorithmName{Anum})

    legend([hhhh,hhhh2,hhhh3],lenstr,Location="best")
    title(AlgorithmName{Anum})

    figure(gca1)
    saveas(gca,['./Picture/',AlgorithmName{Anum},'1.jpg']);
    figure(gca2)
    saveas(gca,['./Picture/',AlgorithmName{Anum},'2.jpg']);
    figure(gca3)
    saveas(gca,['./Picture/',AlgorithmName{Anum},'3.jpg']);
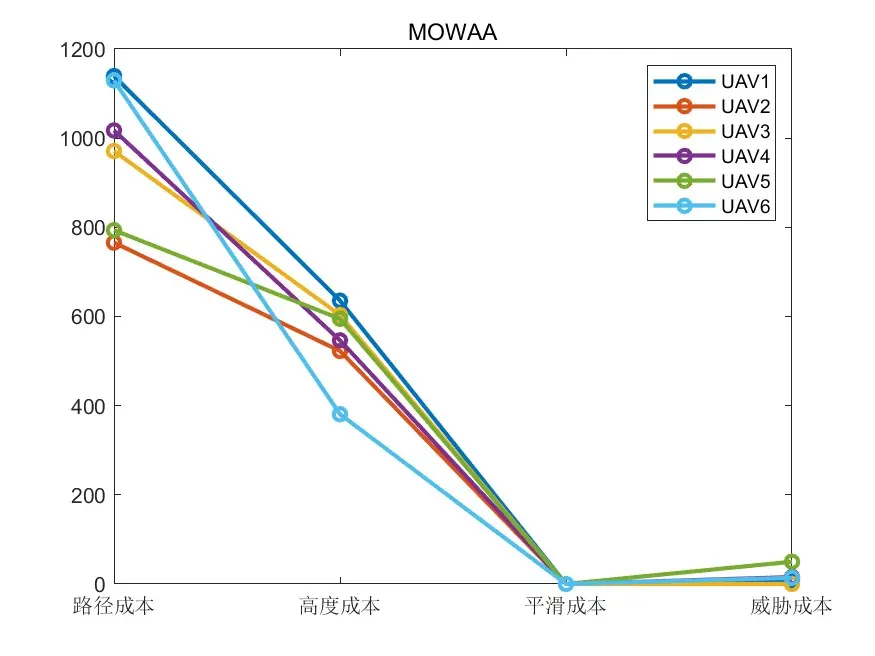
    figure
    for i=1:UAVnum
        plot(Result(i).data.fit,'-o','LineWidth',2)
        hold on
    end
    legend(legenstr)
    set(gca,'xtick',1:1:4);
    set(gca,'XTickLabel',{})
    title(AlgorithmName{Anum})
    saveas(gca,['./Picture/',AlgorithmName{Anum},'5.jpg']);
end


      复制成功
免责声明:本文系网络转载或改编,未找到原创作者,版权归原作者所有。如涉及版权,请联系删
 技术文档
 推荐好文





 155-2731-8020




